Autonomous Food Delivery Robot
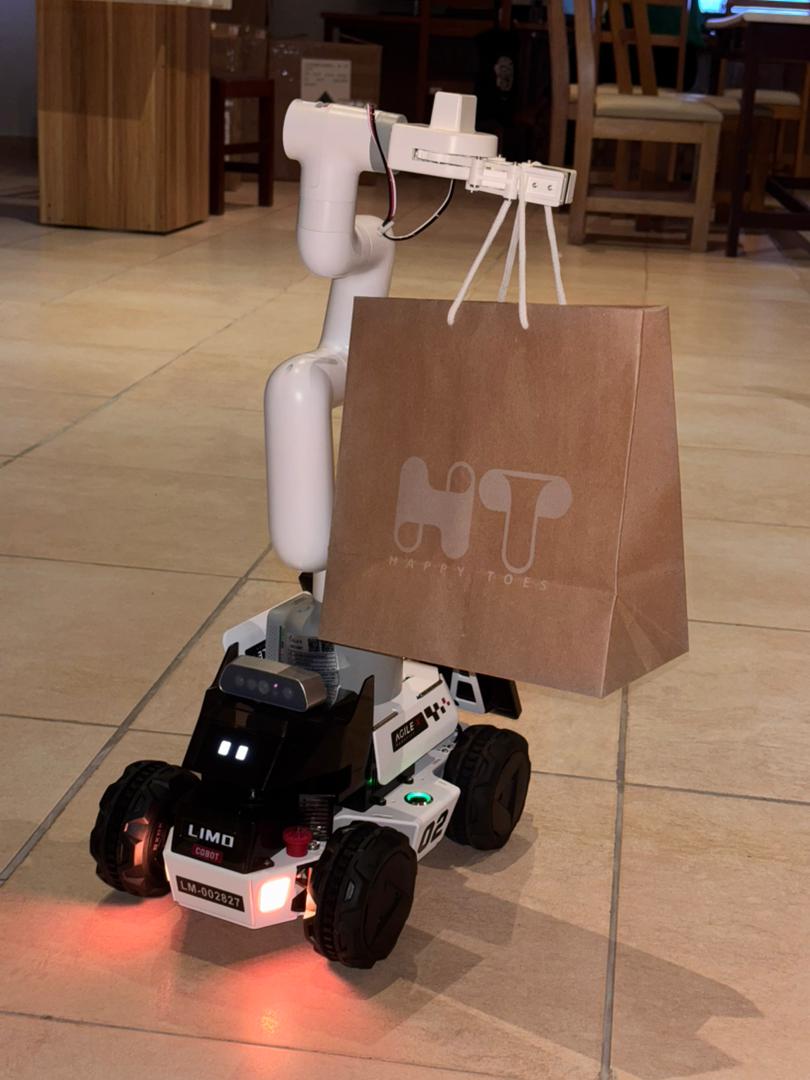
Built an Autonomous Food Delivery Robot using ROS2, A* for path planning, and Dynamic Window Algorithm for obstacle avoidance. A lightweight Flask app managed delivery requests to predefined locations.
ROS2PythonPath PlanningGazeboCAD ModellingBlenderDocker
Full write-up
The full write-up for this project is still being written.