Engineering
Projects documented end to end: requirements, design, testing, and how to reproduce them.
- P-01
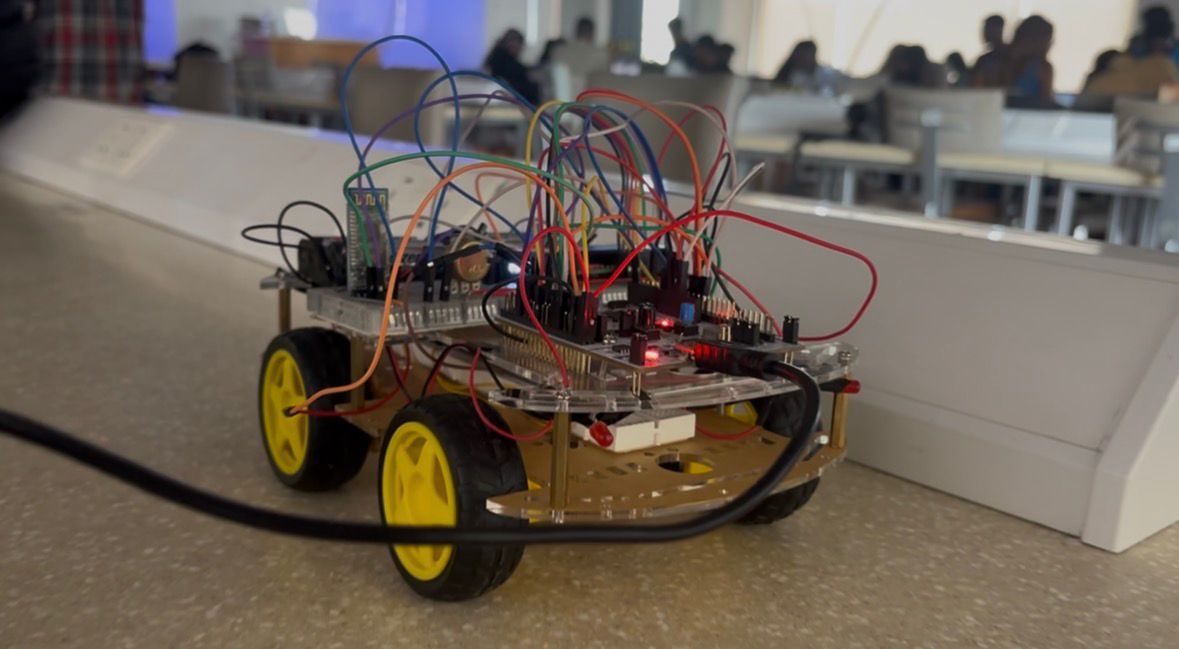
BAT Mobile Robot Cart – Embedded Systems Project
A microcontroller-based robot cart controlled over UART with real-time motor control, lighting indicators, and LCD feedback. The system integrates timers, interrupts, and GPIO to simulate automotive-style behavior such as turn signals and reversing alerts. Designed with modular, reusable embedded C code for easy extension and maintenance.
C ProgrammingBare MetalSTM32UARTOpen project - P-02
Designing a Low-Cost 6-DOF Robotic Arm for Robotics and Control Education
This project presents the design and development of a general-purpose 6-DOF robotic manipulator platform for robotics and control education. The system combines kinematic and dynamic modelling, experimental actuator identification, embedded control, and modular mechanical design to provide an accessible platform for advanced research and hands-on engineering learning.
roboticsmechatronicsrobotic arm6DOFOpen project - P-03
Projects
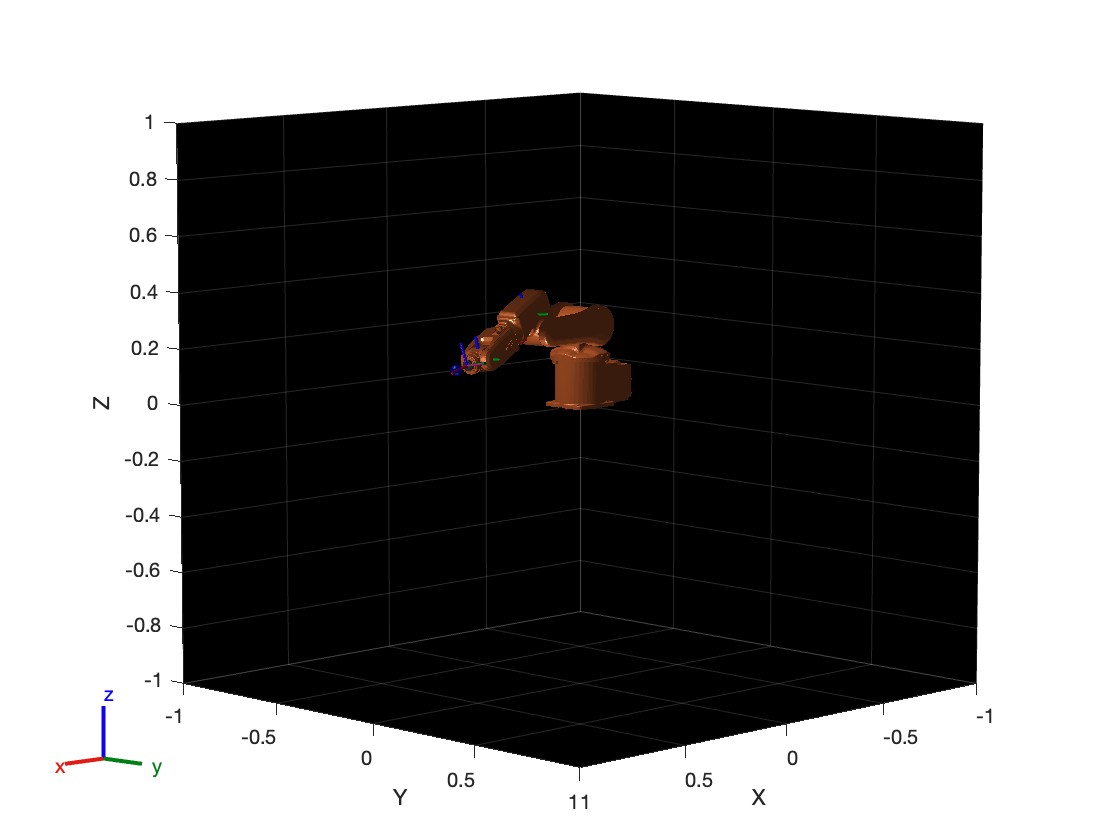
Forward and Inverse Kinematics of the ABB IRB120 Using Numerical Methods
Developed and simulated the forward and inverse kinematics of the ABB IRB120 industrial robot using MATLAB. Forward kinematics was modeled using successive homogeneous transformation matrices. Inverse kinematics was solved numerically using Gradient Descent and Newton–Raphson methods.
MechatronicsKinematicsNumerical MethodsMATLABOpen project - P-04
AI/ML
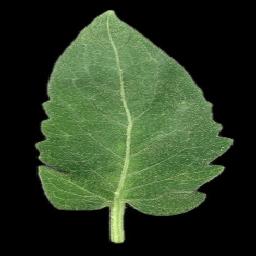
Tomato Doctor 🍅
Built a custom CNN model in Google Colab to classify tomato leaf diseases across 10 classes using a 25K-image dataset. Achieved over 92% accuracy in plant disease identification.
PythonMachine LearningCNNsFlaskOpen project - P-05
Robotics
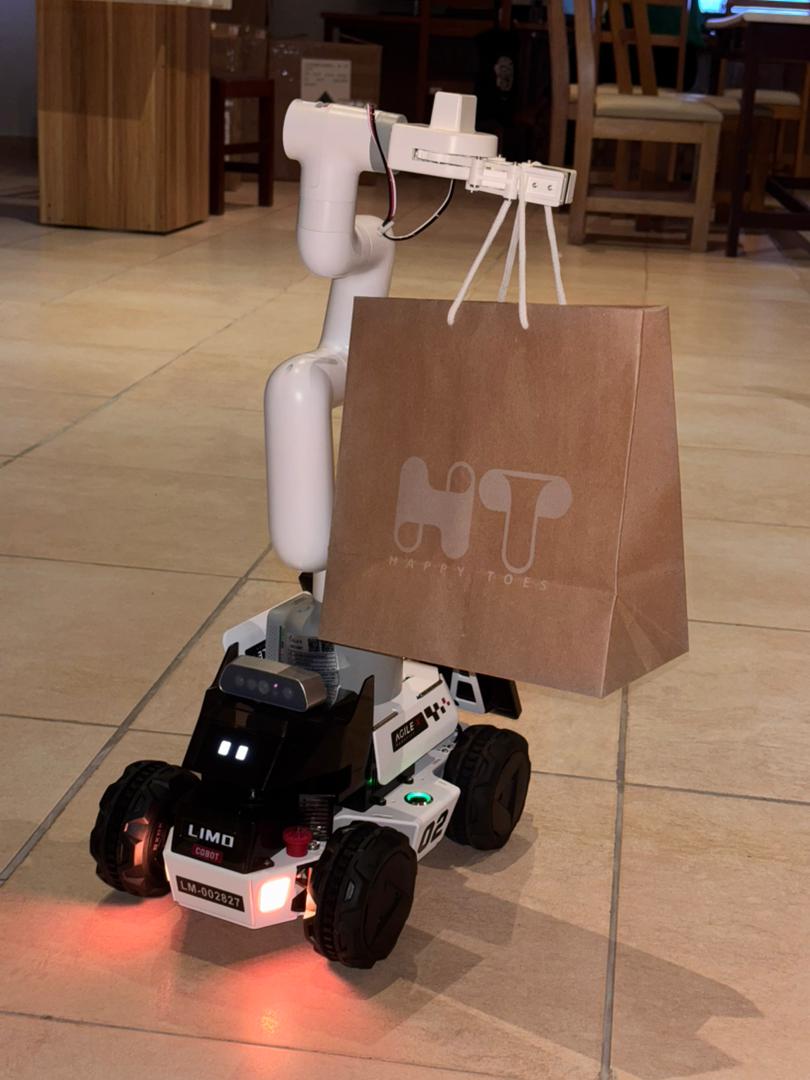
Autonomous Food Delivery Robot
Built an Autonomous Food Delivery Robot using ROS2, A* for path planning, and Dynamic Window Algorithm for obstacle avoidance. A lightweight Flask app managed delivery requests to predefined locations.
ROS2PythonPath PlanningGazeboOpen project - P-06
Control Systems
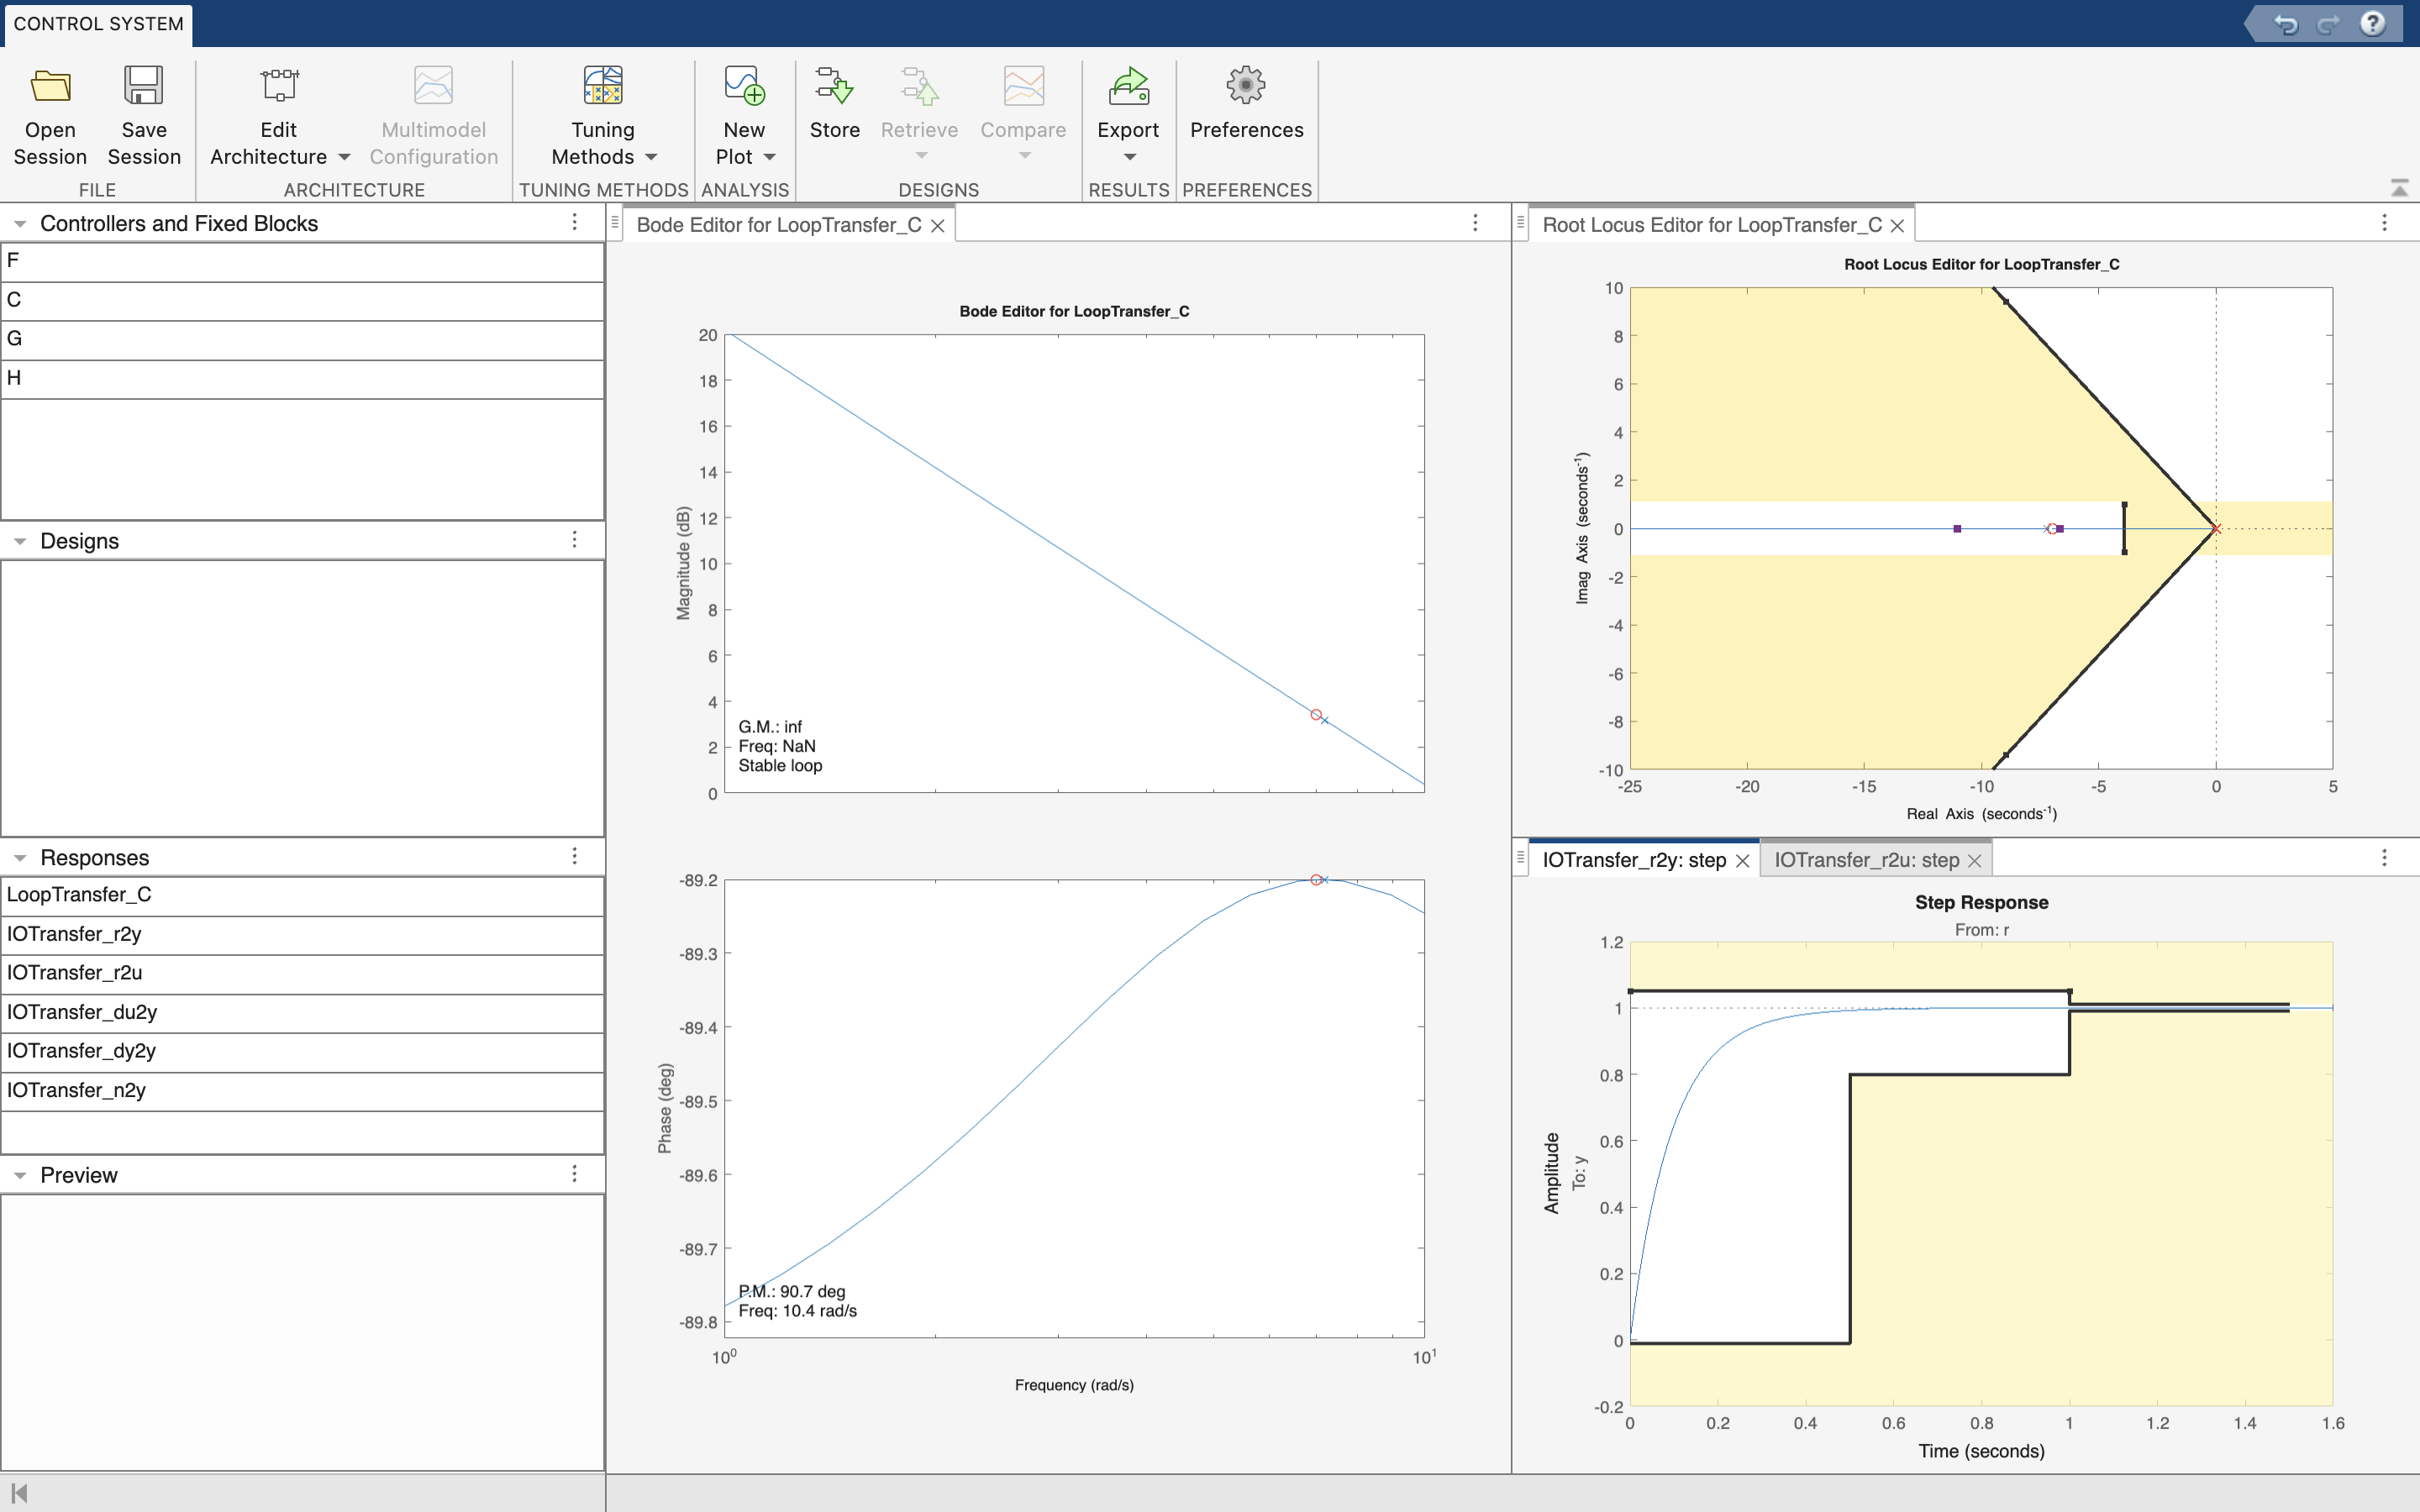
Control System of a Cruise Control System
Integrated multiple sensors, PLCs, and HMI systems to create an automated manufacturing cell with predictive maintenance capabilities.
SCADAPLC ProgrammingIndustrial EthernetHMIOpen project - P-07
Automation
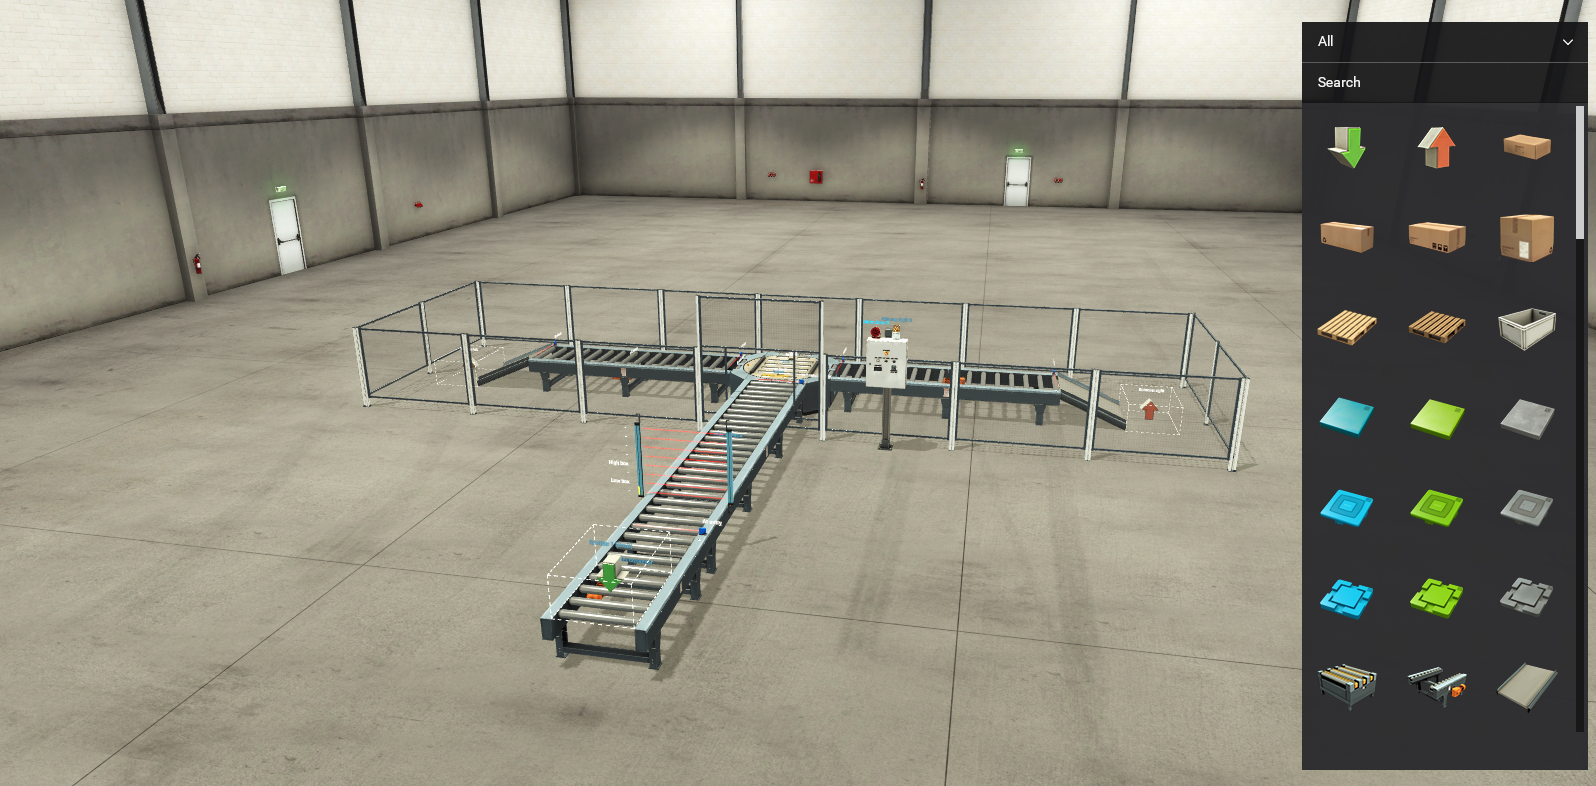
Box Sorting PLC Project
Designed and implemented a PLC-based box sorting system using ISPsoft, Delta PLC, and Kepserver. The system sorts boxes by size and was simulated in Factory I/O for real-time industrial automation.
ISPsoftLadder DiagramsPLCFactory IOOpen project - P-08
Digital Design
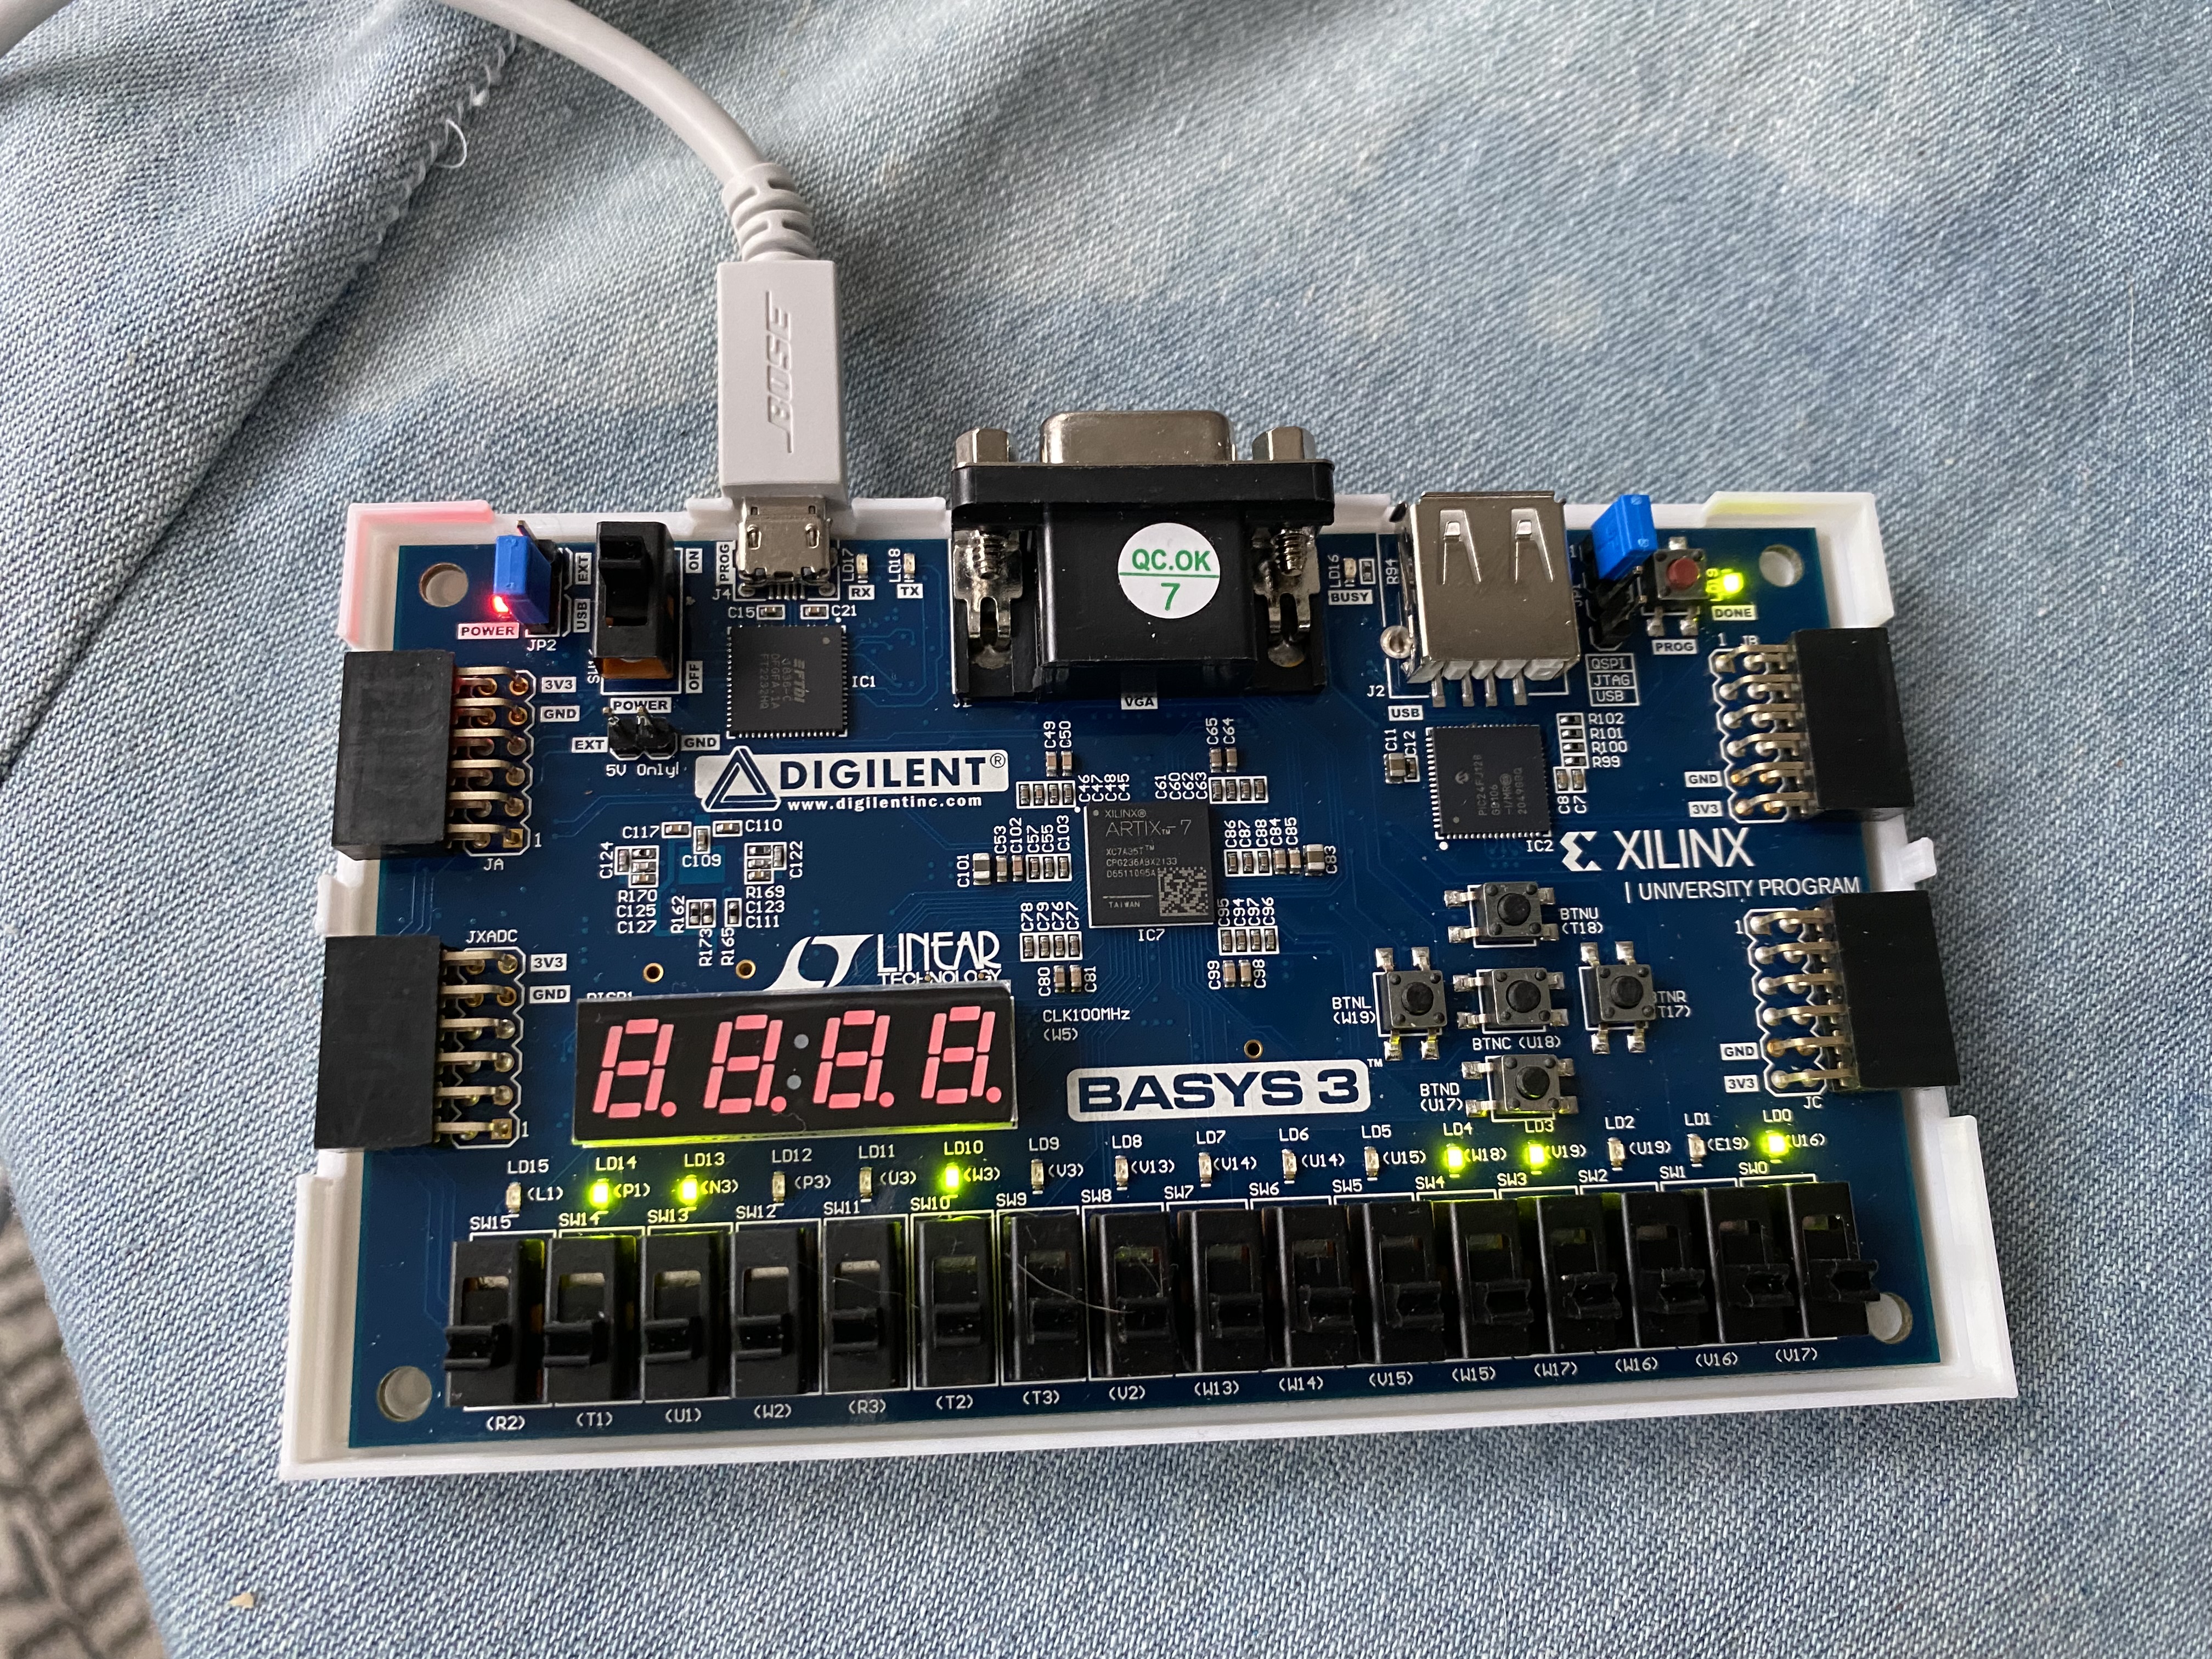
Football Timer Digital System Design
Integrated multiple sensors, PLCs, and HMI systems to create an automated manufacturing cell with predictive maintenance capabilities.
SCADAPLC ProgrammingIndustrial EthernetHMIOpen project - P-09
Signal Processing
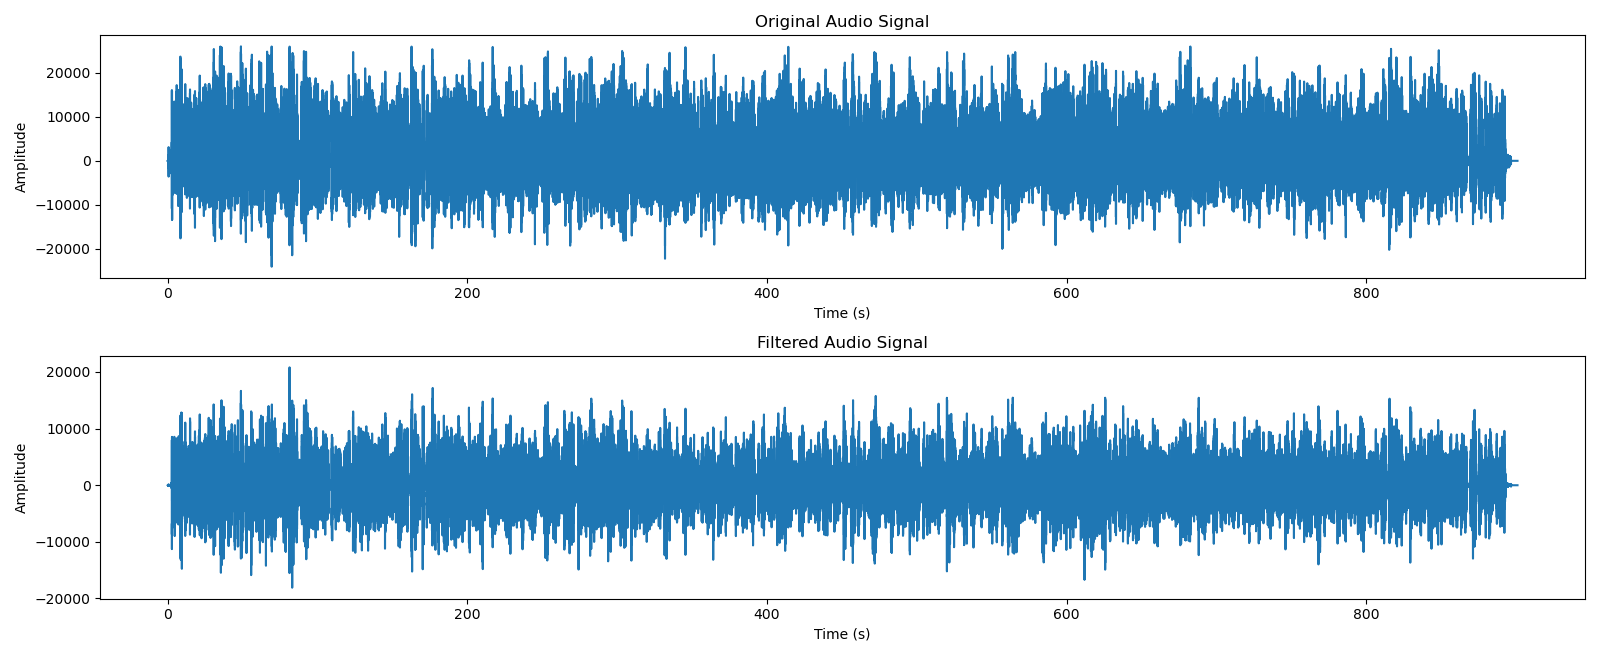
Audio Filter Using FFT
Integrated multiple sensors, PLCs, and HMI systems to create an automated manufacturing cell with predictive maintenance capabilities.
SCADAPLC ProgrammingIndustrial EthernetHMIOpen project